HapTile#
Teleoperated contact-rich manipulation with vision-based tactile fingertips
and the operator’s haptic feedback, as native .mcap episodes.
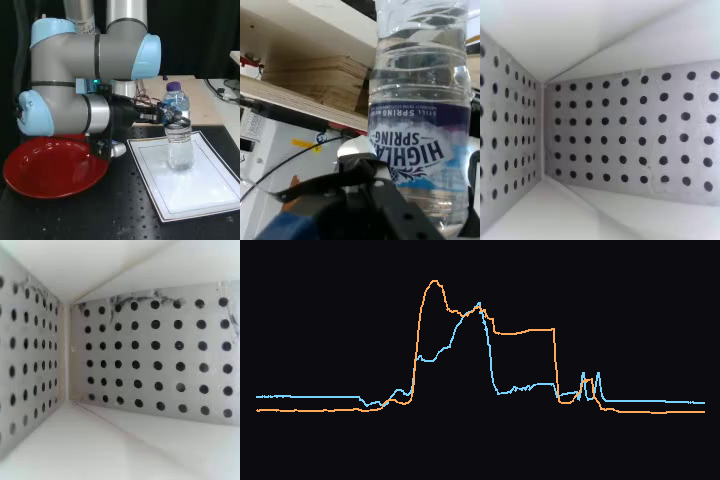
A UR5e arm with a Robotiq 2F-85 gripper works through contact-rich tabletop tasks under teleoperation. Each gripper finger carries a vision-based tactile sensor that films a gel pad printed with a marker grid, so the contact shows as the markers moving. Two RGB-D cameras watch the scene, one facing the table and one on the wrist, and the haptic feedback the operator felt is recorded alongside the robot state and the language instruction.
1,699 episodes across 38 tasks, 664,045 frames, 12.36 hours. The tasks run from inserting a peg and folding a T-shirt to pouring from a bottle and wiping a whiteboard.
Details
Dataset name:
haptileDataset source: https://huggingface.co/datasets/Voxel51/HapTile
Dataset size: 6.32 GB
Dataset license: CC-BY-4.0
Tags:
multimodal, mcap, tactile, haptics, manipulationSupported splits:
N/AZooDataset class:
HapTileDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("haptile")
5
6# The firmest contacts on the right fingertip
7view = dataset.sort_by("peak_marker_motion_right", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load haptile

fiftyone app launch haptile