GrandTour Sample#
A sample of the GrandTour legged robotics dataset, as native .mcap episodes.
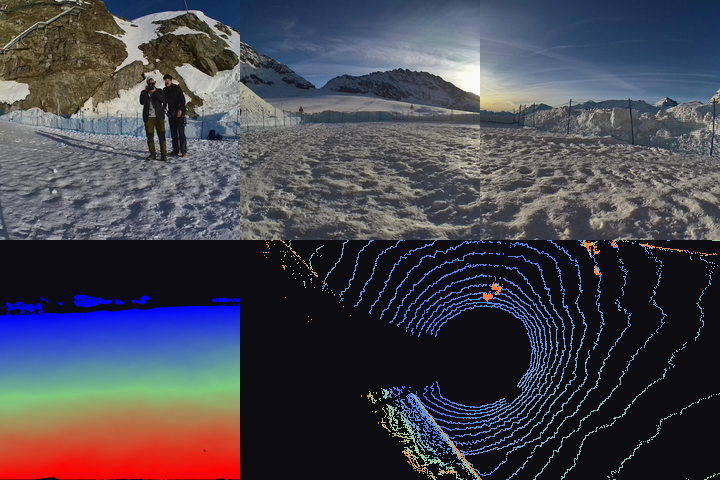
An ANYmal D quadruped from ETH Zurich’s Robotic Systems Lab carries the Boxi sensor payload through cities, buildings, forests, mountains and ice: HDR and depth cameras, a Hesai LiDAR, a tactical-grade inertial unit, a GNSS/INS receiver and the robot’s own joint sensing, with a total station tracking a prism on the payload for reference.
3 missions, 13 minutes 33 seconds of walking, 24,390 HDR camera frames, 12,701 depth frames and 8,363 LiDAR scans holding 433.5 million points. The missions cross ice on the Jungfraujoch, the main hall of ETH Zurich and a muddy forest slope on the Uetliberg.
Details
Dataset name:
grandtour-sampleDataset source: https://huggingface.co/datasets/Voxel51/GrandTour-Sample
Dataset size: 15.92 GB
Dataset license: MIT
Tags:
multimodal, mcap, robotics, legged, lidarSupported splits:
N/AZooDataset class:
GrandTourSampleDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("grandtour-sample")
5
6# The longest walk
7view = dataset.sort_by("lidar_odometry_path_m", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load grandtour-sample

fiftyone app launch grandtour-sample