Hilti SLAM Challenge 2022#
The Hilti SLAM Challenge 2022 recordings, as native .mcap episodes.
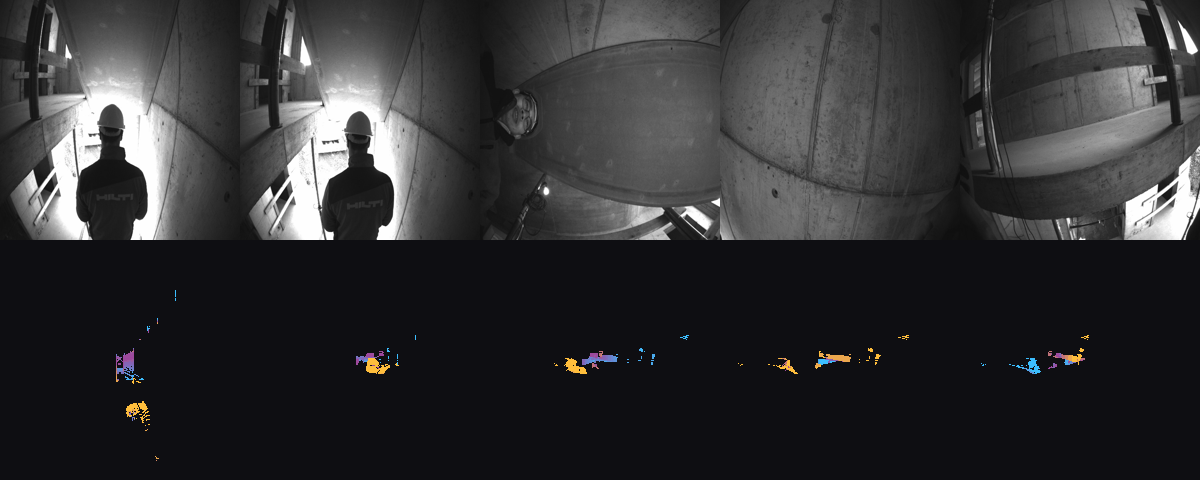
The recordings were made with a handheld rig called Phasma, which carries five synchronized global-shutter cameras, a Hesai PandarXT-32 LiDAR and a Bosch BMI085 IMU. Seven runs were walked through an active construction site in Schaan, Liechtenstein, and nine through the Sheldonian Theatre in Oxford, over five days in March and April 2022. A surveyor measured reference positions along every run, and three runs also carry a continuous reference trajectory.
Camera frames are published at 10 Hz, on the LiDAR’s clock, rather than the
40 Hz the bags record. exp23_the_sheldonian_slam is one run stored as three
episodes sharing a sequence and differing in part, which is why sixteen
runs arrive as eighteen episodes.
Details
Dataset name:
hilti-slam-challenge-2022Dataset source: https://huggingface.co/datasets/Voxel51/Hilti-SLAM-Challenge-2022
Dataset size: 49.70 GB
Dataset license: CC-BY-NC-SA-3.0
Tags:
multimodal, mcap, slam, lidar, imuSupported splits:
N/AZooDataset class:
HiltiSLAMChallenge2022Dataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("hilti-slam-challenge-2022")
5
6# The runs with a continuous reference trajectory
7view = dataset.match({"has_dense_ground_truth": True})
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load hilti-slam-challenge-2022

fiftyone app launch hilti-slam-challenge-2022