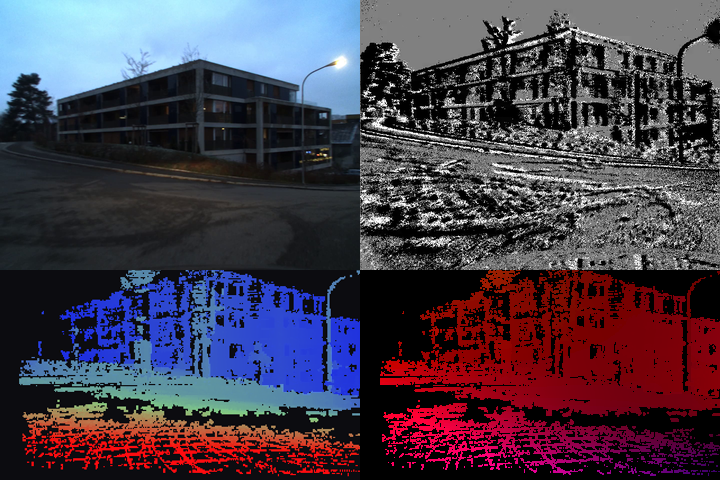
DSEC Sample#
A sample of the DSEC stereo event camera driving dataset, as native .mcap
episodes.
A car carries a stereo pair of Prophesee event cameras at 640x480 and a stereo pair of global-shutter color cameras at 1440x1080 through Zurich, Thun and Interlaken, with disparity ground truth derived from LiDAR for both pairs and, on some sequences, optical flow ground truth for the event cameras. Each episode carries every event of both event cameras as point clouds, one per 1/30 s window, beside a render of each window, with the rectified color images and the ground truth.
6 sequences across Zurich, Thun and Interlaken, 105 seconds of driving, 2,233,378,133 events and 2,112 image pairs.
Details
Dataset name:
dsec-sampleDataset source: https://huggingface.co/datasets/Voxel51/DSEC-Sample
Dataset size: 11.17 GB
Dataset license: CC-BY-SA-4.0
Tags:
multimodal, mcap, event-camera, stereo, drivingSupported splits:
N/AZooDataset class:
DSECSampleDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("dsec-sample")
5
6# The sequences with the busiest event streams
7view = dataset.sort_by("peak_event_rate_mev_s", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load dsec-sample

fiftyone app launch dsec-sample