Edged-USLAM Event Camera#
Quadrotor flights with a DAVIS346 event camera, carrying every event, as
native .mcap episodes.
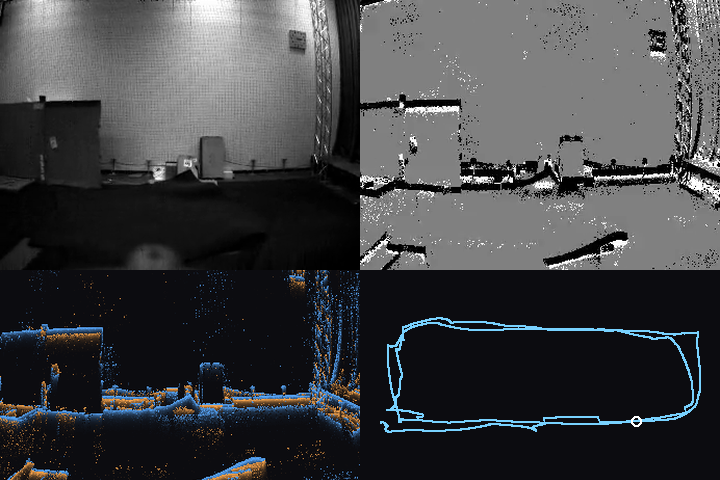
A DAVIS346 event camera rides a quadrotor flown in a motion-capture room. Each run records the camera’s asynchronous events, its grayscale frames and its inertial unit with the Vicon pose of the vehicle, across lines, squares, circles, aggressive turns and manual flights and under lighting from under 5 lux to blinking lights and strong side light. The events are carried as point clouds, one per 1/30 s window, beside a render of each window.
13 runs, 16 minutes 27 seconds of flight, 657,511,373 events and 39,457 frames. The darkest runs show what the event camera adds: where the frames are close to black, the events still trace the room.
Details
Dataset name:
edged-uslam-event-cameraDataset source: https://huggingface.co/datasets/Voxel51/Edged-USLAM-Event-Camera
Dataset size: 4.88 GB
Dataset license: CC-BY-4.0
Tags:
multimodal, mcap, event-camera, uav, roboticsSupported splits:
N/AZooDataset class:
EdgedUSLAMEventCameraDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("edged-uslam-event-camera")
5
6# The darkest runs, where the frames see least
7view = dataset.sort_by("mean_frame_brightness")
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load edged-uslam-event-camera

fiftyone app launch edged-uslam-event-camera