DreamTac#
Contact-rich Franka manipulation with vision-based tactile fingertips, as
native .mcap episodes.
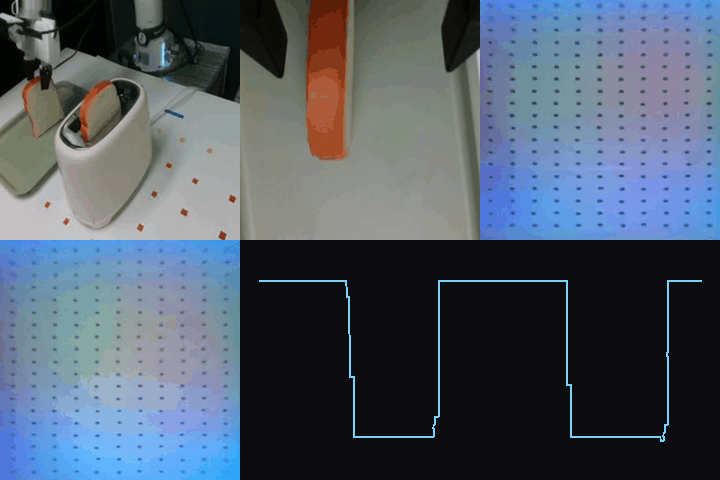
A Franka Emika Panda works through contact-rich tabletop tasks while four cameras record on one 20 fps clock: a third-person view, a wrist view, and two Xense Photon vision-based tactile sensors on the gripper fingertips. Each fingertip is a gel pad printed with a marker grid that deforms where the object presses, so the moment of contact is visible rather than inferred from a force reading.
703 trajectories across 12 tasks, 506,078 frames, 7.03 hours. The tasks run from picking up a baguette or a USB plug to wiping a whiteboard and cutting a banana, and each episode also carries the end-effector pose, the gripper opening and the task instruction.
Details
Dataset name:
dreamtacDataset source: https://huggingface.co/datasets/Voxel51/DreamTac
Dataset size: 2.36 GB
Dataset license: CC-BY-4.0
Tags:
multimodal, mcap, tactile, manipulation, roboticsSupported splits:
N/AZooDataset class:
DreamTacDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("dreamtac")
5
6# The trajectories that moved the furthest
7view = dataset.sort_by("end_effector_path_m", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load dreamtac

fiftyone app launch dreamtac