TUM RGB-D#
The TUM RGB-D SLAM benchmark, as native .mcap episodes.
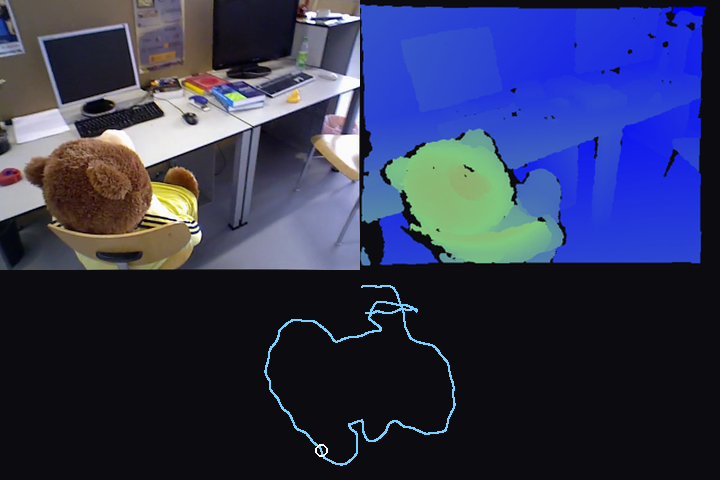
A Microsoft Kinect records color and depth at 640x480 and 30 Hz while an eight-camera motion-capture system tracks it at 100 Hz, handheld, on a Pioneer robot, and over scenes built to test structure against texture, moving people and object reconstruction. Each episode carries the color images, the depth images as the benchmark ships them, the ground-truth pose and the Kinect’s intrinsics, and on the freiburg1 and freiburg2 sequences the Kinect’s accelerometer.
47 sequences in six categories, 48 minutes 12 seconds of recording, 81,413 color frames and 80,683 depth frames.
Details
Dataset name:
tum-rgbdDataset source: https://huggingface.co/datasets/Voxel51/TUM-RGBD
Dataset size: 8.12 GB
Dataset license: CC-BY-4.0
Tags:
multimodal, mcap, rgbd, slam, roboticsSupported splits:
N/AZooDataset class:
TUMRGBDDataset
Example usage
 1import fiftyone as fo
 2import fiftyone.zoo as foz
 3from fiftyone import ViewField as F
 4
 5dataset = foz.load_zoo_dataset("tum-rgbd")
 6
 7# The sequences with people moving through the scene
 8view = dataset.match(F("category") == "Dynamic Objects")
 9
10session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load tum-rgbd

fiftyone app launch tum-rgbd