TartanGround#
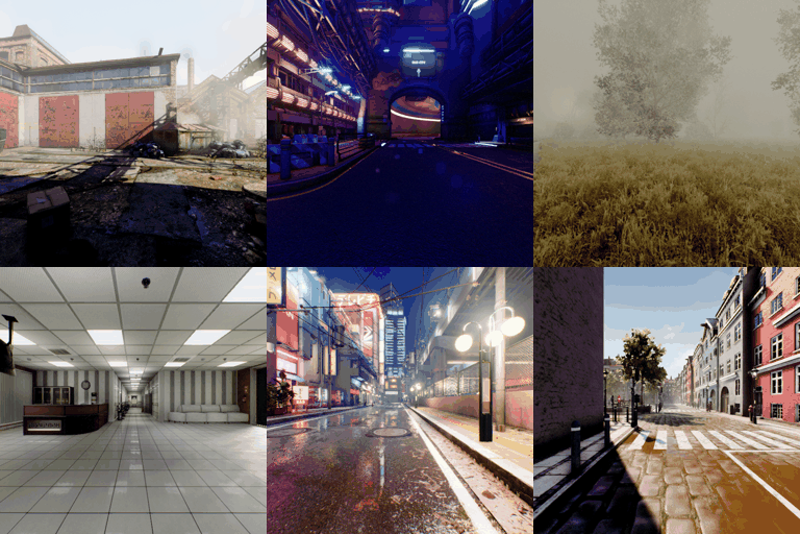
Six trajectories from the TartanGround ground-robot dataset, one per
simulation environment (AbandonedFactory, CyberPunkDowntown, GreatMarsh,
Hospital, JapaneseCity, NordicHarbor), as native .mcap episodes.
Each episode carries the front camera, its segmentation stream, per-frame lidar point clouds, ego pose, and IMU plot channels on a 10 Hz frame clock.
Details
Dataset name:
tartangroundDataset source: https://huggingface.co/datasets/Voxel51/TartanGround
Dataset size: 7.24 GB
Dataset license: CC-BY-4.0
Tags:
multimodal, mcap, robotics, lidar, simulationSupported splits:
N/AZooDataset class:
TartanGroundDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("tartanground")
5
6session = fo.launch_app(dataset)
fiftyone zoo datasets load tartanground

fiftyone app launch tartanground