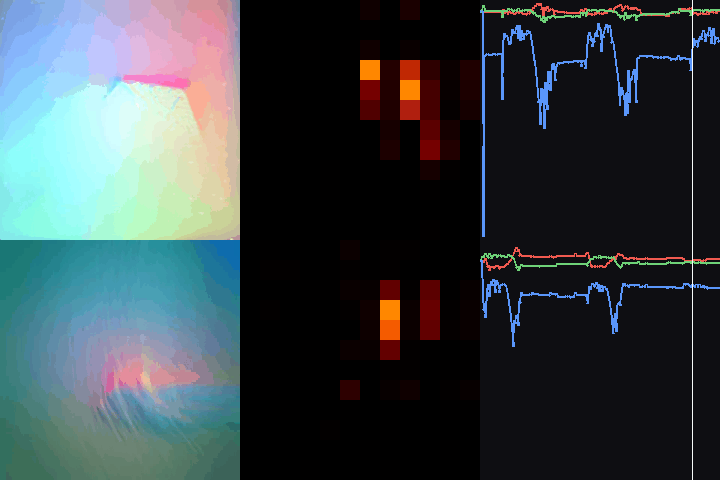
TaF Tactile-Force#
Contact-rich probing runs pairing tactile sensing with measured force, as
native .mcap episodes.
Every frame carries what a tactile sensor sees and what a force sensor measures at the same instant: a vision-based tactile image, a 12x12 piezoelectric pressure map locating the contact, and a six-axis wrench from an ATI sensor. Contacts reach 90.8 N and 1.58 Nm.
3,594 episodes across 408 sequences, 10,057,742 frames, 93.1 hours. Six sensor configurations are represented, spanning the GelSight Mini with and without markers and a custom sensor with several marker grids.
Details
Dataset name:
taf-tactile-forceDataset source: https://huggingface.co/datasets/Voxel51/TaF-Tactile-Force
Dataset size: 41.65 GB
Dataset license: MIT
Tags:
multimodal, mcap, tactile, force-torque, manipulationSupported splits:
N/AZooDataset class:
TaFTactileForceDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("taf-tactile-force")
5
6# The firmest contacts
7view = dataset.match({"peak_force": {"$gt": 50}})
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load taf-tactile-force

fiftyone app launch taf-tactile-force