ColoRadar Sample#
A sample of the ColoRadar 3D millimetre-wave radar dataset, as native .mcap
episodes.
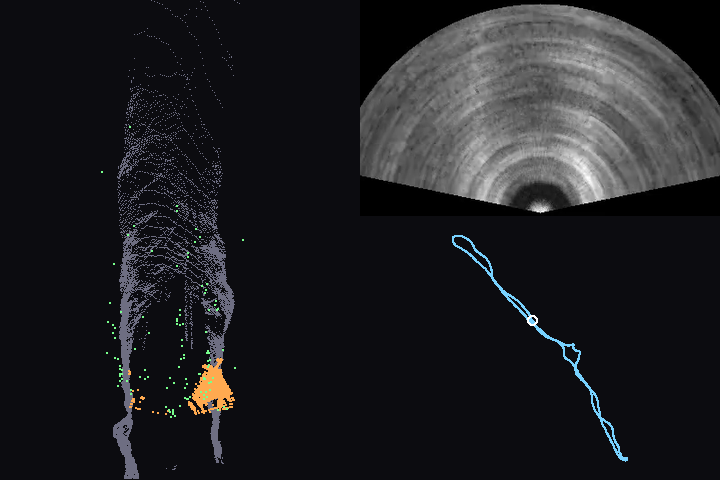
A handheld rig carries a TI cascaded imaging radar and a TI single-chip radar beside an Ouster OS1-64 LiDAR and a Microstrain inertial unit, through hallways, a lab, a motion-capture space, outdoor built environments, the narrow and the large passages of an underground mine, and a fast ride along paths and roads. Each episode carries both radars’ point clouds, a top-down render of each cascaded radar heatmap, the LiDAR scans, the inertial unit and the release’s LiDAR-inertial ground truth.
7 sequences, one from each of the seven places the release records, 13 minutes 46 seconds of recording, 8,263 LiDAR scans holding 382.6 million points, 4,145 cascaded radar frames and 8,340 single-chip radar scans.
Details
Dataset name:
coloradar-sampleDataset source: https://huggingface.co/datasets/Voxel51/ColoRadar-Sample
Dataset size: 6.47 GB
Dataset license: Apache-2.0
Tags:
multimodal, mcap, radar, lidar, roboticsSupported splits:
N/AZooDataset class:
ColoRadarSampleDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("coloradar-sample")
5
6# The sequences that covered the most ground
7view = dataset.sort_by("ground_truth_path_m", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load coloradar-sample

fiftyone app launch coloradar-sample