NTNU Underwater Multi-Camera#
Piloted underwater robot runs with five cameras and an inertial unit, as
native .mcap episodes.
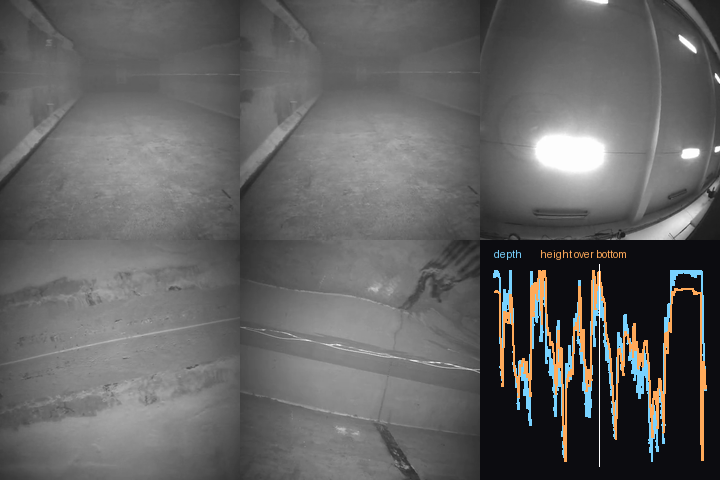
Ariel, the NTNU Autonomous Robots Lab’s underwater robot built on the BlueROV2 Heavy configuration, is piloted through the Trondheim Fjord and the Marine Cybernetics Laboratory pool. An Alphasense rig records five monochrome cameras, a forward stereo pair and cameras looking up, left and right, with a 200 Hz inertial unit, while the vehicle’s autopilot logs a second inertial unit, a barometer, a downward rangefinder and the thruster outputs. Each run carries the authors’ ReAqROVIO reference trajectory and the rig’s calibration.
8 runs, 6 in the fjord and 2 in the pool, 63 minutes 19 seconds of recording, 379,896 camera frames and 759,943 inertial samples over 1,439 m of reference trajectory.
Details
Dataset name:
ntnu-underwater-multicamDataset source: https://huggingface.co/datasets/Voxel51/NTNU-Underwater-Multicam
Dataset size: 1.31 GB
Dataset license: BSD-3-Clause
Tags:
multimodal, mcap, underwater, robotics, slamSupported splits:
N/AZooDataset class:
NTNUUnderwaterMulticamDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("ntnu-underwater-multicam")
5
6# The deepest dives
7view = dataset.sort_by("max_depth_m", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load ntnu-underwater-multicam

fiftyone app launch ntnu-underwater-multicam