M3ED Sample#
A sample of M3ED, the multi-robot, multi-sensor, multi-environment event
camera dataset, as native .mcap episodes.
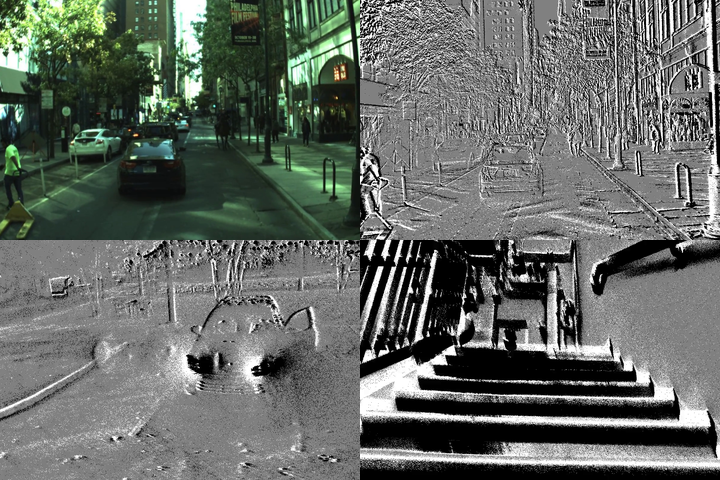
A car, a quadrotor and a Boston Dynamics Spot carry the same sensor head: a stereo pair of Prophesee event cameras at 1280x720, a stereo pair of grayscale cameras and a color camera at 1280x800, an inertial unit and an Ouster OS1-64 LiDAR. Each episode carries every event of both event cameras as point clouds, one per 1/30 s window, beside a render of each window, with the cameras, the LiDAR scans and the ground-truth poses and depth.
3 sequences, one per platform: a city street by day, a quadrotor flight outdoors at night and an indoor stairwell, 192 seconds in all with 3,631,437,863 events, 4,802 image triplets and 1,921 LiDAR scans.
Details
Dataset name:
m3ed-sampleDataset source: https://huggingface.co/datasets/Voxel51/M3ED-Sample
Dataset size: 22.13 GB
Dataset license: CC-BY-SA-4.0
Tags:
multimodal, mcap, event-camera, stereo, lidarSupported splits:
N/AZooDataset class:
M3EDSampleDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("m3ed-sample")
5
6# The sequences with the busiest event streams
7view = dataset.sort_by("peak_event_rate_mev_s", reverse=True)
8
9session = fo.launch_app(dataset, view=view)
fiftyone zoo datasets load m3ed-sample

fiftyone app launch m3ed-sample