CitrusFarm Sample#
A sample of the CitrusFarm multimodal agricultural robotics dataset, as a
native .mcap episode.
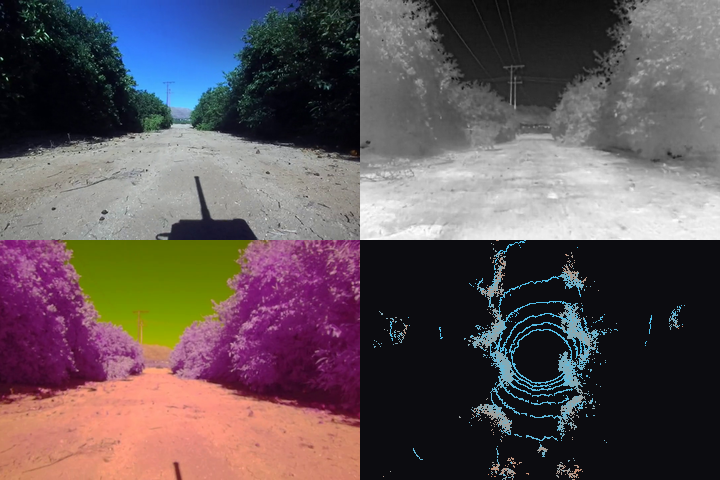
A Clearpath Jackal drives the rows of citrus trees at the University of California Riverside’s Agricultural Experimental Station carrying a monochrome camera, a thermal camera, a camera that sees red, green and near-infrared, a ZED 2i stereo camera with its depth, a Velodyne LiDAR, an inertial unit and a GPS-RTK receiver. The episode carries every camera, the stereo depth, the LiDAR scans, the GPS-RTK fixes, the wheel and visual odometry and the ground-truth trajectory on one clock.
One sequence, 5 minutes of driving over 357 m: 3,026 monochrome, 3,024 thermal, 3,025 red-green-NIR and 3,022 stereo frames and 2,998 LiDAR scans.
Details
Dataset name:
citrusfarm-sampleDataset source: https://huggingface.co/datasets/Voxel51/CitrusFarm-Sample
Dataset size: 2.50 GB
Dataset license: CC-BY-SA-4.0
Tags:
multimodal, mcap, agriculture, thermal, multispectral, lidarSupported splits:
N/AZooDataset class:
CitrusFarmSampleDataset
Example usage
1import fiftyone as fo
2import fiftyone.zoo as foz
3
4dataset = foz.load_zoo_dataset("citrusfarm-sample")
5
6session = fo.launch_app(dataset)
fiftyone zoo datasets load citrusfarm-sample

fiftyone app launch citrusfarm-sample